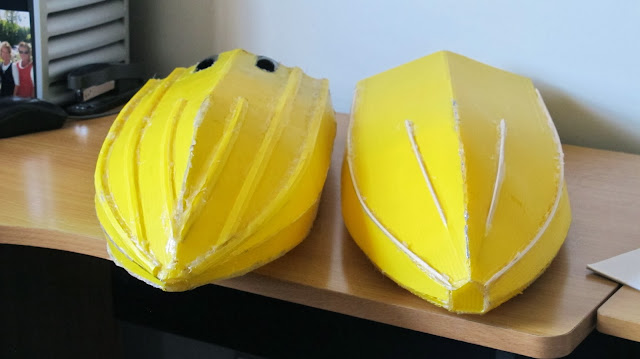
Blue Boat 1 a single piece of Coroflute
Showing posts with label yellow. Show all posts
Thursday, March 24, 2016
Someone else building a Yellow boat in Blue Coroplast
Blue Boat 1 a single piece of Coroflute
Yellow boat 1 and 2
Yellow Boat 3
Yellow Boat 4 Balsa ply Epoxy Fiberglass tape
Sunday, March 20, 2016
Yellow boat 4 Arduino code with HK TR6 A V2 RX PPM interface
Im lowering the top BTW
The build here
Arduino Inputs from RX
Ch3 Throttle Arduino pin 4
Ch1 Steering Arduino pin 5
Ch5 Throttle limit Arduino pin 6
Ch2 Steering on Throttle Arduino pin 7
Arduino analogue inputs
Anin 0 Ambient temp sensor Anin 1 Hall effect current sensor


Ch5 Throttle limit Arduino pin 6
Ch2 Steering on Throttle Arduino pin 7
Arduino analogue inputs
Anin 0 Ambient temp sensor Anin 1 Hall effect current sensor


Arduino outputs
Pin 8 Left jet
Pin 9 Right jet
Pin 10 Cooling fan speed
Pin 11 Steering
Mixing of the outputs
//SteeringBias
int SterringOnThrottle = (long)map((int)ch4v, 1500, 1100, 0, 1000);
if(SterringOnThrottle < 0) SterringOnThrottle = 0;
SteeringBias = (long)map((int)ch3v - (int)ch3vWOZ, 0, 1000, 0, SterringOnThrottle);
int SteeringAngle = (long)map((int)ch3v, 1100, 1900, 1000, 2000);
//Limit fan speed for 11.1 V
FanSpeed = map(FanSpeed, 1100, 1900, 1000, 1500);
//Update the outputs
Servo1.writeMicroseconds((int)Throttle - (int)SteeringBias);
Servo2.writeMicroseconds((int)Throttle + (int)SteeringBias);
Servo3.writeMicroseconds((int)FanSpeed);
Servo4.writeMicroseconds((int)SteeringAngle);
The cooling system


The fan is a 27 mm EDF should keep the air moving with a 10A ESC
There is a big heatsink and fan on the 30 AMp ESCs
Wednesday, March 16, 2016
Yellow boat 4 FPV camera view Purau New Zealand 2 1 14
Yellow boat 4 mostly Hobby King bits balsa epoxy fiber glass hull
http://kiwitricopter.blogspot.co.nz/2012/09/3-hour-yellow-boat.html
Twin Turnigy 450 Series 3800KV Brushless Outrunner Helicopter Motor
RPM: 3800kv
Max Current: 35A
Max Power: 365W
2 X HobbyKing 30A BlueSeries Brushless Speed Controller with shared enlarged air cooled heatsink with an 30mm fan
Cont. Current: 30A
Burst Current: 40A
http://www.hobbyking.com/hobbyking/store/uh_viewitem.asp?idproduct=13429&aff=652823
coupled to modified NQD jet drives with flex shafts and custom 3 blade impellers
ZIPPY Compact 2700mAh 3S 25C Lipo Pack
Capacity: 2700mAh
Voltage: 3S1P / 3 Cell / 11.1V
Discharge: 25C Constant / 35C Burst
Weight: 203g (including wire, plug & case)
Dimensions: 137x15x44mm
Balance Plug: JST-XH
http://www.hobbyking.com/hobbyking/store/uh_viewitem.asp?idproduct=21349&aff=652823
Purau
https://www.google.co.nz/maps/preview#!q=Purau%2C+Canterbury&data=!4m15!2m14!1m13!1s0x6d322f14fc09c6a3%3A0x500ef868479e4b0!3m8!1m3!1d338144!2d175.3085223!3d-37.6203018!3m2!1i1366!2i642!4f13.1!4m2!3d-43.6390402!4d172.7489035
Yellow boat 4 FPV camera view Purau New Zealand 2-1-14 from nickatredbox on Vimeo.
Saturday, March 5, 2016
Mad Man Yellow Boat 2 X Turnigy Heli motors 700 Watts 1850 Grams of thrust measured at 78 Amps
Mad Man Yellow Boat 2 X Turnigy Heli motors > 700 Watts 1850 Grams of thrust measured at 78 Amps

Turnigy Heli series outrunner motors are an excellent upgrade for your helicopter. Built with high quality components, tight windings and genuine NMB ball bearings, these motors provide excellent performance and efficiency at a price that cant be beat! Specs:
Operating Voltage: 7.4~14.8V (2~4S lipoly)
RPM: 3800kv
Max Current: 35A
Max Power: 365W
Idle Current: 3.5A
Resistance: 0.018ohms
Shaft: 3.175mm
3mm flex shafts 3 blade impellers cutdown props 45mm pitch

Sunday, February 28, 2016
Yellow Boat 4 twin NQD jets driven by P2632 Brushless Outrunner 3800kv Brushless
Yellow Boat 4
Twin NQD jets modified with brass stern tubes.
I have alternate nozzels which are a little larger than standard also.

Brass impellers made from cutdown brass props
Two P2632 Brushless Outrunner 3800kv Brushless
Stern Tubes brass shafts wrapped in PTFE tape until they fit the tubes. Will be setting up air cooling system with small EDF fan.
Will probably run two 2200mAh Lipos and 50 Amp aero ESCs with big heatsinks
For the cooling I may have the Arduino open and close a vent with a servo if the heatsinks get hot, as well as controlling the fan speed.
Based on yellow boat plans different deck 390 Grams as shown
Also Ply fiberglass epoxy catamaran build log
Glass and epoxy inside balsa ply, will epoxy the outside too. Its very strong with builders fiberglass tape and epoxy
Also Ply fiberglass epoxy catamaran build log
Glass and epoxy inside balsa ply, will epoxy the outside too. Its very strong with builders fiberglass tape and epoxy
The motors will be mounted further forward on a cooled plate
Spray rails are bamboo barbecue skewers and wood filler
Sunday, February 14, 2016
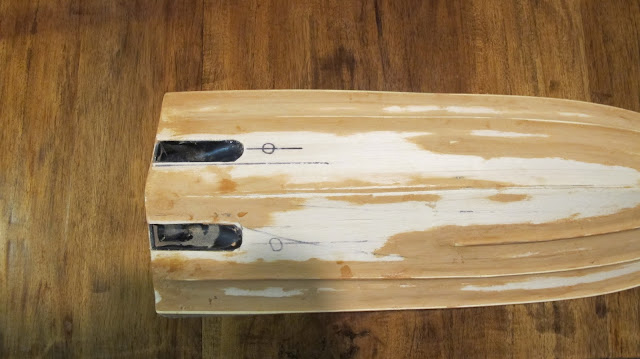
Wood and fiberglass hull like yellow boat
Based on yellow boat plans different deck 390 Grams as shown
Also Ply fiberglass epoxy catamaran build log
Yellow boat 3 http://kiwitricopter.blogspot.co.nz/2012/12/yellow-boat-3-power-test-scratch-built.html
Fit out http://kiwitricopter.blogspot.co.nz/2013/12/mad-man-yellow-boat-2-x-turnigy-heli.html
Sea run a Purau http://kiwitricopter.blogspot.co.nz/2014/01/yellow-boat-4-fpv-camera-view-purau-new.html
Another run at Motunau http://kiwitricopter.blogspot.co.nz/2014/01/yellow-boat-4-motunau.html
Evo 2 http://kiwitricopter.blogspot.co.nz/2014/01/yellow-boat-4-revised-powertrain.html
Glass and epoxy inside balsa ply, will epoxy the outside too. Its very strong with builders fiberglass tape and epoxy
The motors will be mounted further forward on a cooled plate
Spray rails are bamboo barbecue skewers and wood filler
Will be powered with 2 of the following
P2632 Brushless Outrunner 3800kv
The Arduino code will be the same as I ran in the Catamaran I may add differential thrust with steering angle as its a twin
#include
int ch1 = 4;
int ch2 = 5;
unsigned long ch1v;
unsigned long ch2v;
unsigned long RightLeft = 0;
unsigned long UpDown = 0;
long Trim = 0;
long Throttle = 0;
long Cooling = 0;
long PumpSpeed = 0;
Servo Servo1;
Servo Servo2;
Servo Servo3;
Servo Servo4;
#define MAX_CHAN 8
int AnIn[MAX_CHAN] = {0, };
unsigned long PPMtout = 20000;
char buf[300] = {0, };
long mS = 0;
void setup() {
Serial.begin(115200);
pinMode(ch1, INPUT);
pinMode(ch2, INPUT);
Servo1.attach(8);
Servo2.attach(9);
Servo3.attach(10);
Servo4.attach(11);
}
void loop() {
AnIn[0] = analogRead(A0);
AnIn[1] = analogRead(A1);
AnIn[2] = analogRead(A2);
AnIn[3] = analogRead(A3);
AnIn[4] = analogRead(A4);
AnIn[5] = analogRead(A5);
AnIn[6] = analogRead(A6);
AnIn[7] = analogRead(A7);
/* RAZU-2 Six turn
This device has a gain of 55mV per amp giving a 36 Amp working range,
and a resolution of 11.3777 mA per bit with the maximum output at 5 volts
which is 1024 bits in the Arduino. By the way I should point out that
these devices on a 5 volt rail will sit around 2.5 volts with no current
flowing, so at a 2 Volt delta the out put should be around 4.5 V
*/
mS = micros();
//Get PPM from each RX channel
noInterrupts();
ch1v = pulseIn(ch1, HIGH, PPMtout);//Throttle
if(ch1v > 0)
{
ch2v = pulseIn(ch2, HIGH, PPMtout);//Imax
}
else//Fail safe
{
ch1v = 1000;
ch2v = 1000;
}
interrupts();
//ALLOW INTERRUPTS BEFORE UPDATE SERVOS
delayMicroseconds(2000);
//Calculate motor amps
long Motor_mA = ((long)(AnIn[1] - 512) * 11.0f);
int Tmax = (int)ch2v;
//Set max throttle
Throttle = (long)map((int)ch1v, 1000, 2000, 1400, Tmax);
//Calc amps
long Amps = (long)map((int)Motor_mA, 0, 36000, 0, 36);
//Calculate cooling temp RTC on AnIn[0]
int cerr = ((int)600 - (int)AnIn[0]);
//Integrate temparature
Cooling += cerr;
if(Cooling < 1000) Cooling = 1000;
else if(Cooling > 2000) Cooling = 2000;
//Use the temperature integrator plus the motor current
//36 Amps gives us 360 bits
PumpSpeed = (long)Cooling + (Amps * 10);
//Update the outputs
Servo1.writeMicroseconds((int)Throttle);
Servo2.writeMicroseconds((int)PumpSpeed);
long Cyc_mS = (micros() - mS);
//ALLOW SERVOS TO UPDATE BEFORE INTERRUPTS OFF
delayMicroseconds(18000 - Cyc_mS);
Cyc_mS = (micros() - mS);
sprintf(buf, "ch1v_Tmax:%d,ch2v_Imax:%d,Throttle:%d,AnIn[0]:%d,AnIn[1]:%d,CoolingError:%d,Cooling:%d,Imax:%d,MotorAmps:%d,Cyc_mS:%d", (int)ch1v, (int)ch2v, (int)Throttle, AnIn[0], AnIn[1], cerr, (int)Cooling, (int)Tmax, (int)Amps, (int)Cyc_mS );
Serial.println(buf);
/*
char incomingByte = 0;
// send data only when you receive data:
while (Serial3.available() > 0) {
// read the incoming byte:
incomingByte = Serial3.read();
Serial.print((char)incomingByte);
delayMicroseconds(1000);
if(incomingByte == 13) break;
}
Serial.println( );
*/
}
Posted by andre at 7:45 PM 0 comments
Labels: and, boat, Boat Plans, fiberglass, hull, like, wood, yellow
Subscribe to:
Posts (Atom)